 Yanheng Zhu
My team
NYU Shanghai
Robotics Club · RoboMaster
I lead our RoboMaster algorithm team, working on sentry perception, navigation, embedded control, and decision-making.
02 / Projects
Robot systems and engineering projects spanning perception, navigation, real-time control, and decision-making.
My team
Robotics Club · RoboMaster
I lead our RoboMaster algorithm team, working on sentry perception, navigation, embedded control, and decision-making.
Collaboration
VIP ARC Robotics
We are helping ARC build its robots. Their team is also using my open-source sentry software.
Joint team
Preparing for DJI RMUC 2027
We collaborate with university robotics teams through The Great Lakes alliance, preparing together for next season.
01RoboMaster · ROS2
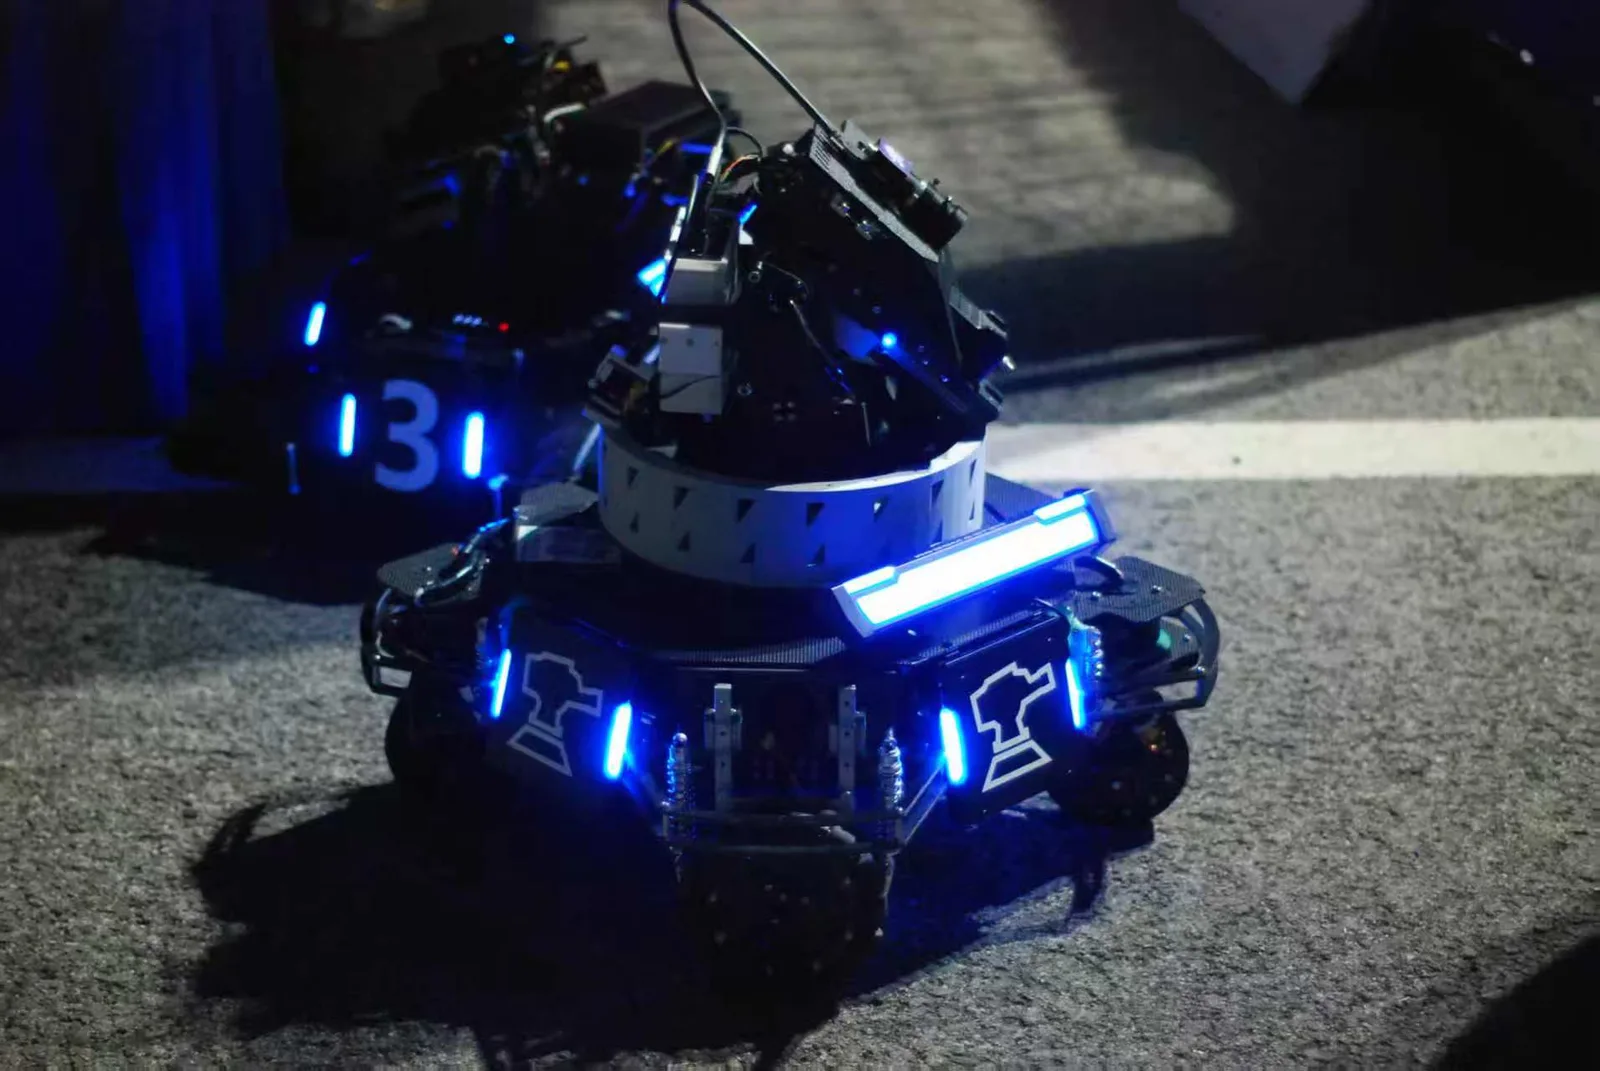
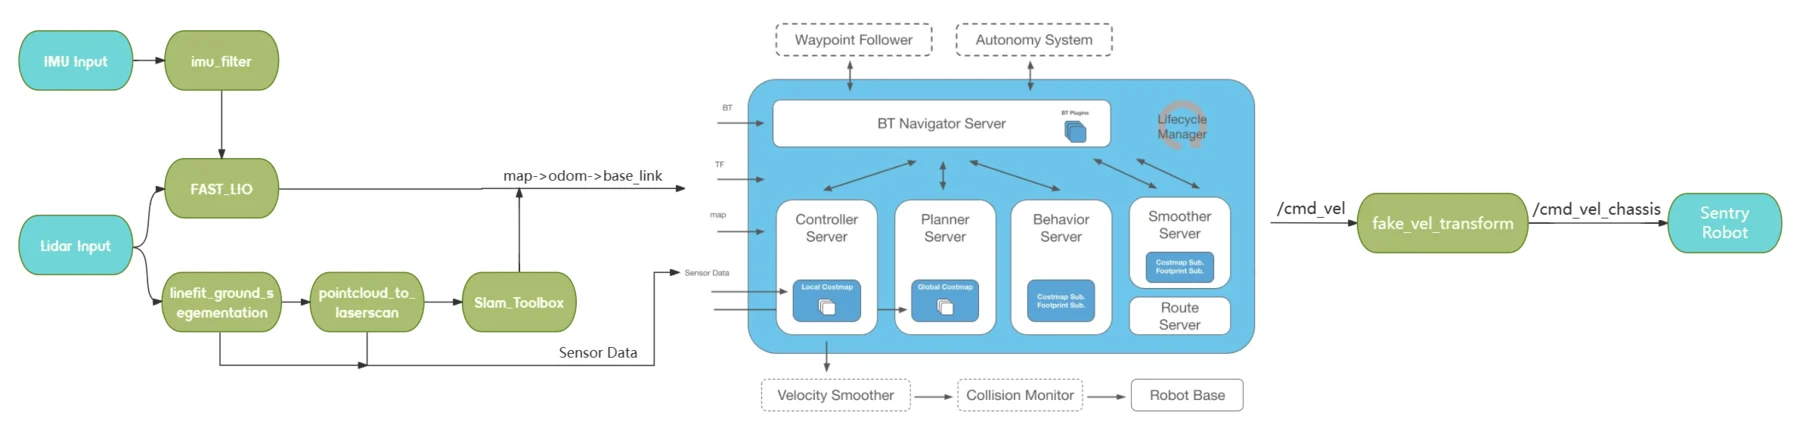
I built the sentry's perception and navigation system, adapting open-source auto-aim to our hardware and competition setup. I connected detection and tracking with our localization, navigation, and deployment software built around Mid-360, FAST-LIO, and Nav2.
02RoboMaster · STM32
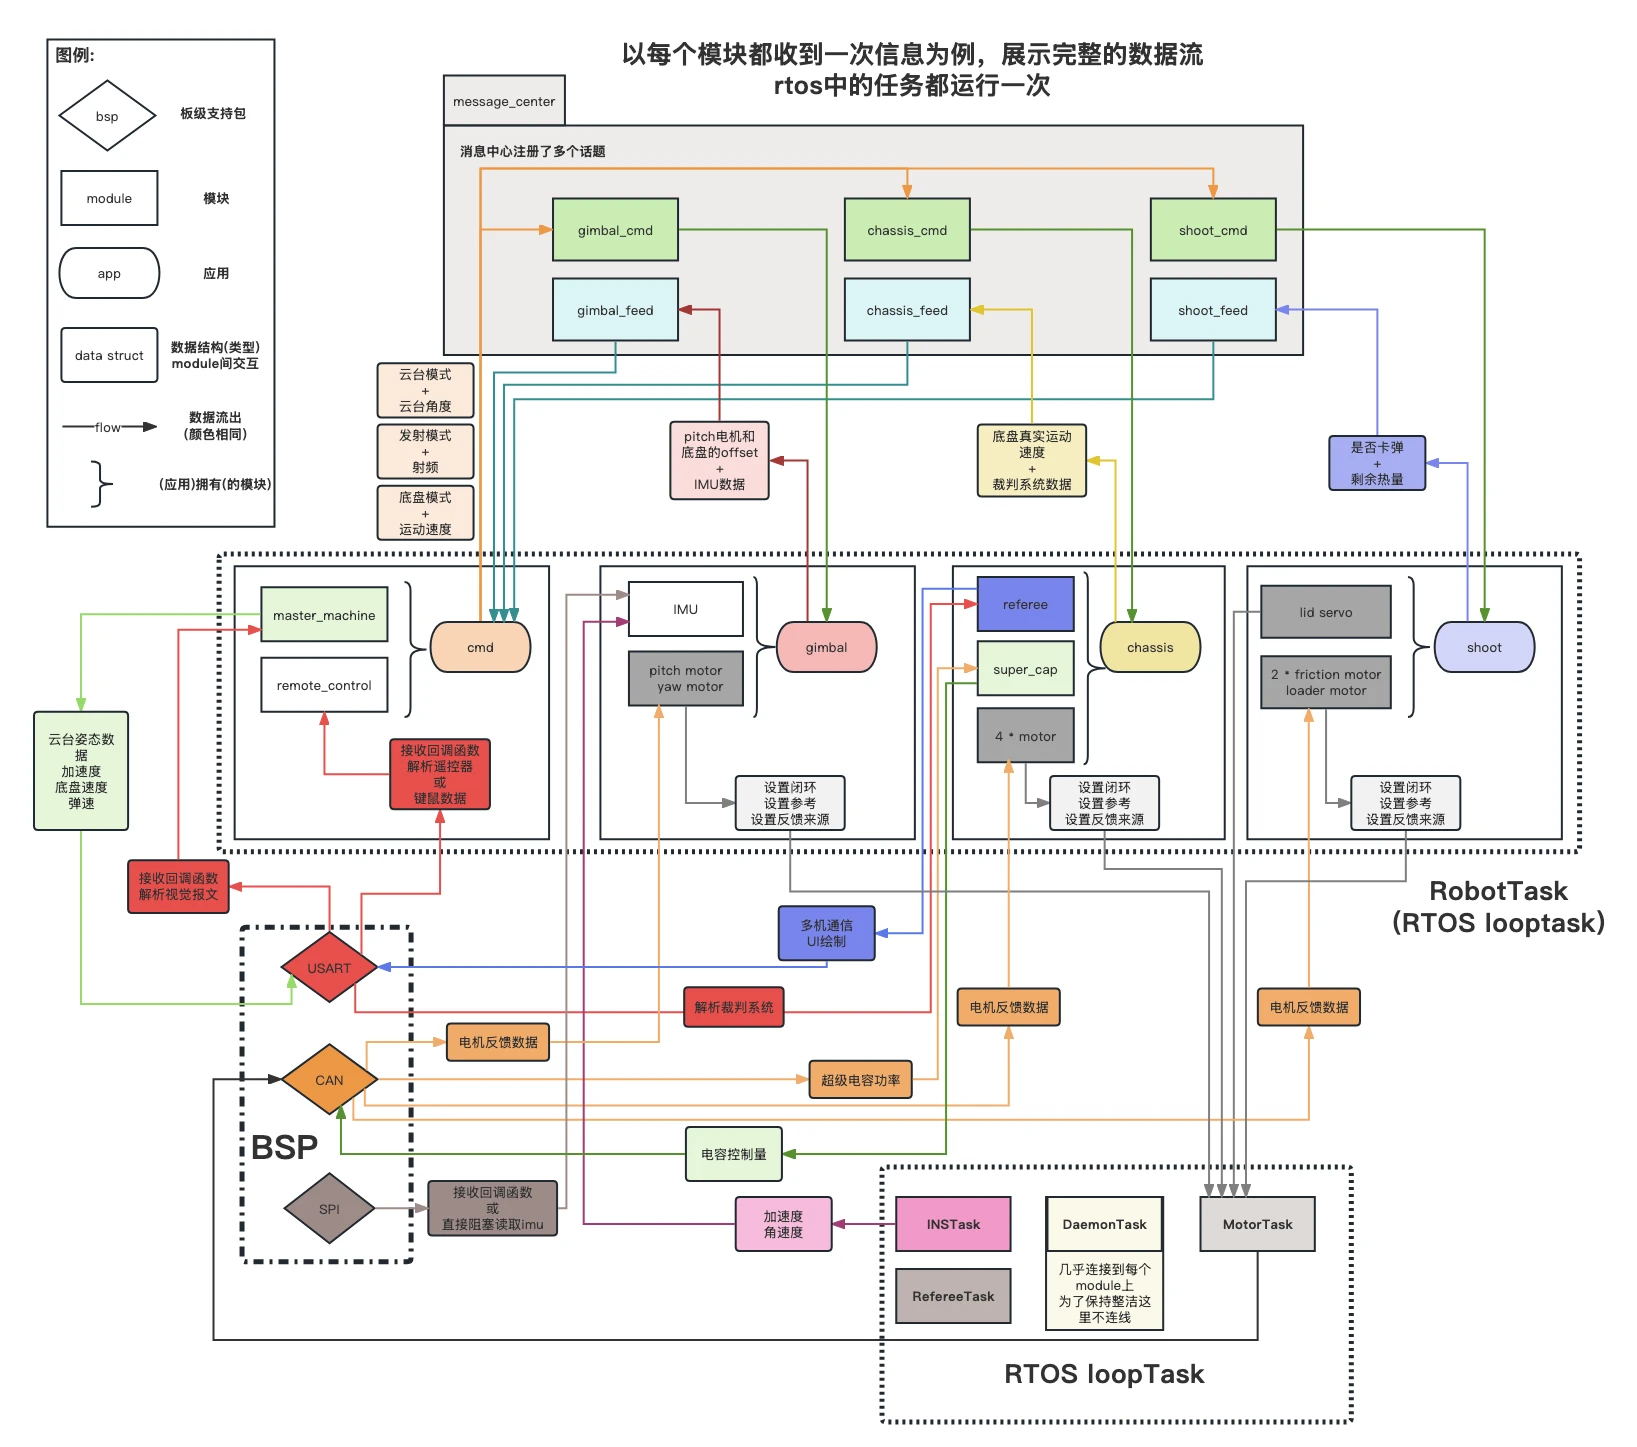
I developed STM32 and FreeRTOS firmware for the sentry's chassis, gimbal, and shooter. Our largely in-house communications and safety systems connect the onboard computer to real-time motor control, with watchdogs and failsafes.
03RoboMaster · Decision
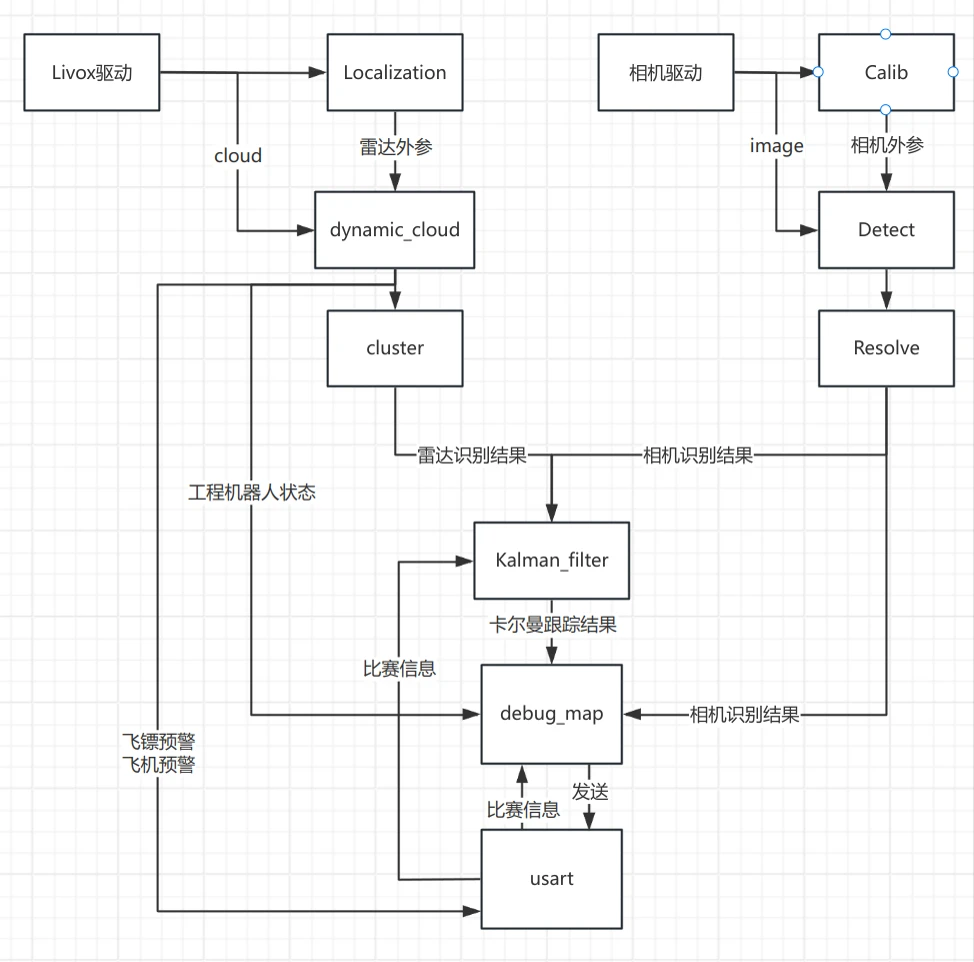
I developed a radar pipeline that aligns Mid-360 point clouds with camera detections, then fuses and tracks targets with a Kalman filter. In the sentry stack, BehaviorTree.CPP turns match state and perception into navigation goals and robot actions.
04Unitree Go2
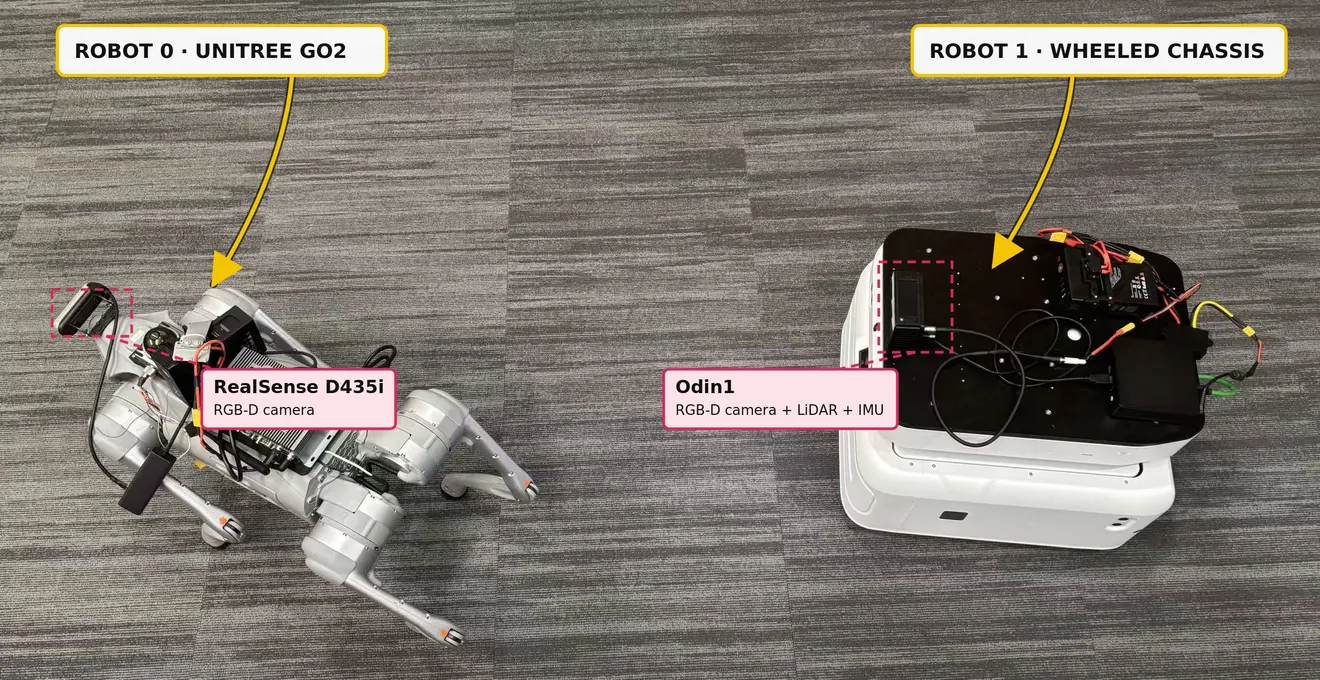
I adapted TinyNav to Unitree Go2 and replaced stereo depth with streaming monocular depth from LingBot. Relocalization, planning, control, and safety stops now run as one deployable ROS2 loop.
05MCM · Problem C
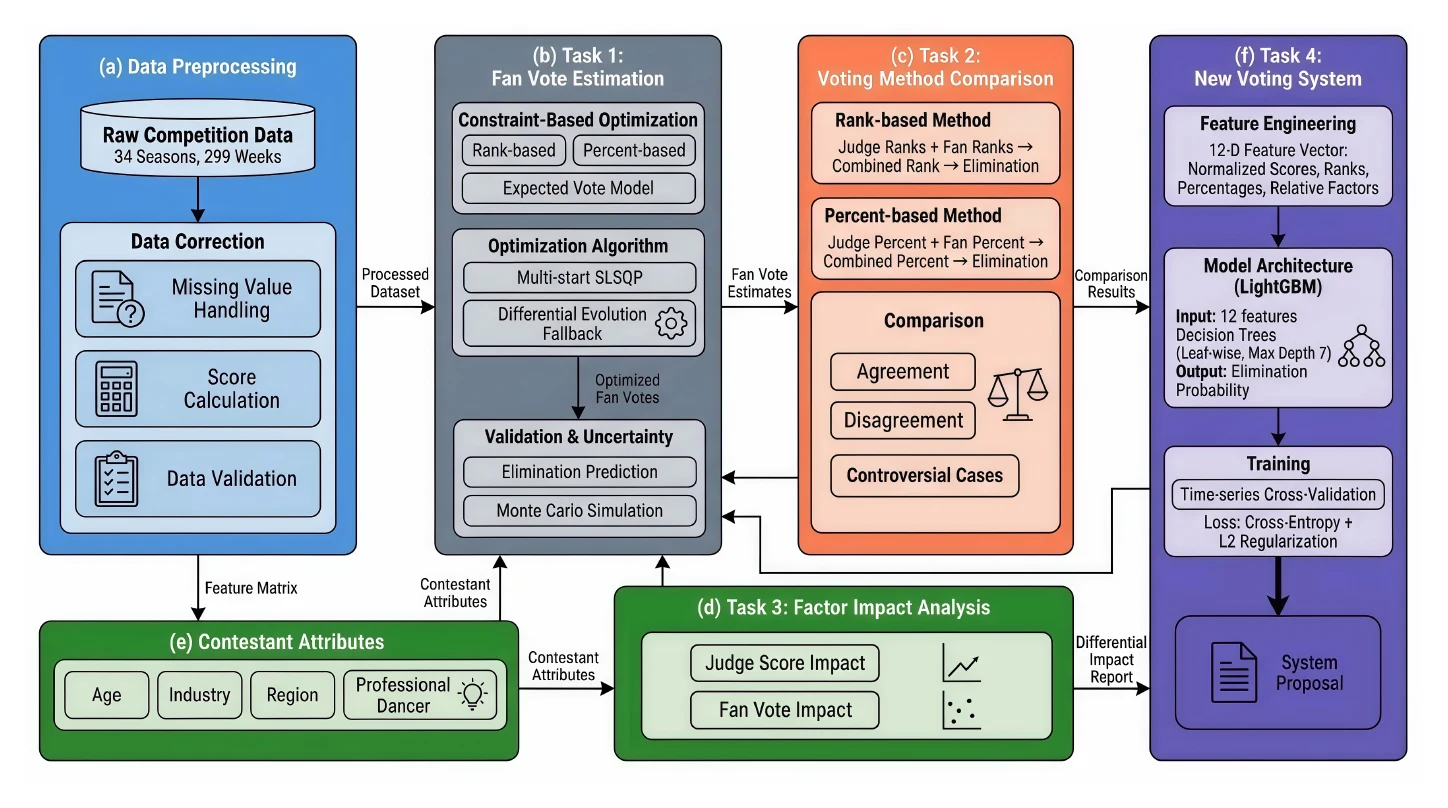
For COMAP's 2026 MCM, our team used inverse optimization and LightGBM to study hidden fan votes, elimination rules, and voting-system design. The work received a Meritorious Winner award.
· Scene reconstruction
This project builds a digital twin of our lab from measured RGB, LiDAR and motion data. The pipeline aligns point clouds, maps, meshes, and semantic layers, and adapts DirectFisheye-GS for native fisheye Gaussian Splatting.
Demo: full-scene lab reconstruction.
· Object-goal navigation
A single-robot navigation stack derived from my TopoFocus real-world system. It combines VLM-guided exploration and spatial memory with A* routing, TinyNav local planning and guarded chassis control to search for target objects.
The demo shows field runs from the original system. The standalone release still awaits full robot validation.
3DGS · Real-to-sim
A calibration-light monocular reconstruction prototype combining cuVSLAM tracking, LingBot geometry, GenWildSplat, and Gaussian Splatting for scene reconstruction and inspection.
Audio ML · PyTorch
An audio classification ensemble using spectrograms, pseudo-labels, and teacher-student training. It placed 4th in the course's Kaggle competition.
A prompt-to-Manim visual learning tool with generated narration, FastAPI streaming, and a browser interface.